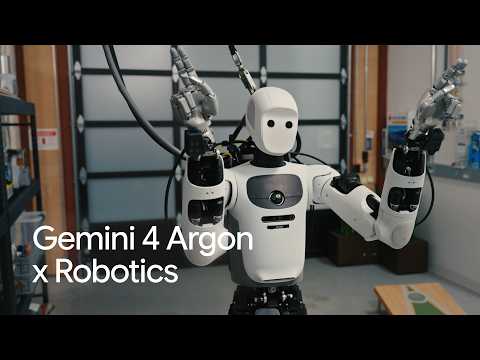
 📺 Teaching a humanoid robot to play cornhole with Gemini 4 Argon
Teaching a Humanoid Robot to Play Cornhole
▼
An experiment explores whether Gemini 4 can help a humanoid robot learn to throw bean bags into a cornhole board. The process combines human-video observation, simulation practice, and adjustments based on real-world throws.
- Human motion mapping and camera-based measurement of the board
- Simulated practice to refine the robot’s stance and throwing motion
- Real-world trials and adjustments based on where the bags land
For viewers interested in robotics, AI, or learning through simulation, this offers an overview of the experiment’s workflow. It focuses on the cornhole task rather than detailed hardware specifications or a general guide to robot programming; viewers can use the stages described as a framework for examining similar experiments.
この動画を紹介した Google DeepMind の最新動画も、紹介付きで読めます。
📄 このページの紹介文は AI が独自に生成したものであり、著作権をはじめとする他者の権利(商標権・名誉権・プライバシー等)を侵害しないよう配慮しています。動画の著作権は各作成者に帰属します。